Map building
Map building builds a map from a horizon, from well markers or from a point set in a single dialog, with its own set of parameters. Open it on the Modelling ribbon tab, in the Mapping group, by clicking Map building.
The dialog stays open while you work, so you can build a map, look at the result and build the next one without reopening it. The parameters are kept with the project. The General tab holds the input data and the main build parameters, and the Advanced tab holds the settings of the selected algorithm.
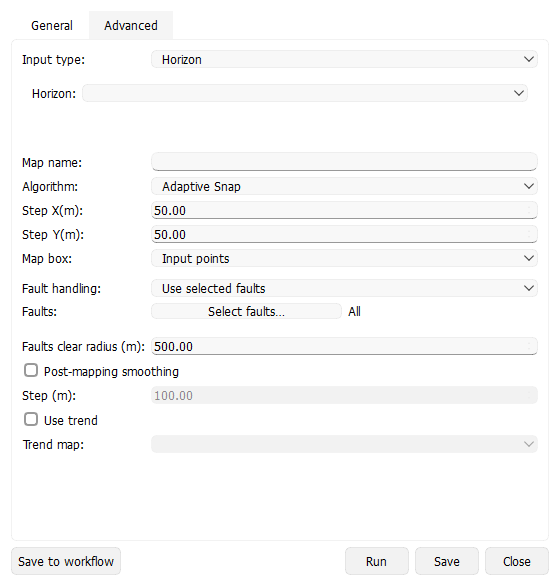
Input data
Input type sets the kind of data the map is built from. The controls beneath it change with the selection:
- Horizon — select one of the project horizons in the Horizon list.
- Well markers — select a marker of the active marker set in the Marker list, then the value to map in Attribute. The attribute list offers MD, TVD, TVDSS, TWT and the attributes of the marker itself; TVDSS is used by default.
- Points — select a point set in Point set and one of its numeric columns in Attribute.
Map name is the name of the resulting map. It follows the selected input object until you type a name of your own, and it must not be empty when the map is built.
Build parameters
- Algorithm — ABOS, Kriging or Adaptive Snap. New projects use Adaptive Snap by default. The Advanced tab always shows the settings of the algorithm selected here.
- Step X and Step Y — the cell size of the resulting map, 50 m by default in new projects. Saved project settings are retained. These boxes, and every other distance in the dialog, are labelled and entered in the distance unit of the project, so an imperial project shows the same default in feet.
- Map box — the area the map covers: Input points (the extent of the input data), All bins (the whole survey, which requires a defined survey bounding box) or Polygon, which adds a Polygon list for choosing the outline.
Fault handling
Select in Fault handling how faults constrain the map:
- Ignore faults — faults are not used and the map is continuous across them. The remaining fault controls are hidden.
- Use selected faults — click Select faults… and tick the faults to use. Each selected fault that intersects the mapped surface leaves a permanent NoData gap along its trace, regardless of its assigned type. Unticked faults are excluded when at least one fault is ticked. The label beside the button shows how many faults are ticked, or All when nothing is ticked and every fault of the project is used. Rebuilding an existing map applies the same type-independent gap behavior.
- Use fault model — use the surfaces of the model selected in Fault model as the barrier framework. Each model fault that intersects the mapped surface leaves a permanent NoData gap along its trace, regardless of fault type.
- Fault polygon — use the outlines of the polygon selected in Fault polygon as the barriers.
With every option except Ignore faults the Faults clear radius box appears. It controls the band cleared around each barrier to remove noisy values. Cleared cells outside the permanent fault trace are rebuilt from reliable data on the same side of the barrier; the trace itself remains NoData with Use selected faults and Use fault model.
Smoothing and trend
Post-mapping smoothing smooths the finished map, and Step sets the width of the smoothing window. The option is cleared by default.
Use trend builds the map on top of a regional surface: the map selected in Trend map is subtracted from the input data, the difference is interpolated and the trend is added back. The trend map must hold the same kind of values as the input data, so a depth input needs a depth trend map. Input points that the trend map does not cover are not used, and their number is reported when the map is built. The option is cleared by default.
Advanced
The Advanced tab shows the settings of the algorithm selected on the General tab:
- ABOS — Use nearest, Max error, Number of iterations, Factor, Taper size, Smooth aperture, Smoothing iterations and Smoothing Q.
- Kriging — Covariance (Spherical, Gaussian or Exponential), Range and Max points.
- Adaptive Snap — Fault mode (Ignore, Barrier or Final refinement only) and Density (Auto, Sparse (wells) or Dense (grid)).
Building the map
- Run — saves the settings, builds the map and leaves the dialog open.
- Save — saves the settings without building a map and leaves the dialog open.
- Save to workflow — adds the configured Map building step to the current workflow, or updates the step when opened from a workflow. Select an input object and enter a map name first. This does not build a map immediately.
- Close — closes the dialog without building a map or saving unsaved changes.
After a successful build, the Mapping ribbon group uses the algorithm and steps used to build the map. Saving settings or saving a workflow step does not update these ribbon values; neither does a failed or cancelled build.
The result is saved in the Data Manager: depth horizons, depth columns of point sets, and marker TVD or TVDSS values produce Depth maps; time horizons, time columns of point sets, and marker TWT values produce Time maps. Other attributes produce Calculated maps. When building interactively, you are asked whether to overwrite a map of the same name in the destination folder. A workflow run keeps the existing map and gives the new result a unique name.
See Also